RESEARCH · ETRI project
Isaac Sim Autonomous-Driving Simulation
Isaac Sim Autonomous-Driving Simulation
Environment & ROS Interface
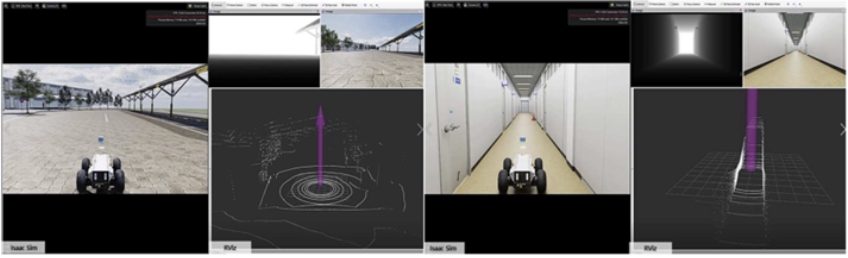
- Rebuilt a 3D-scanned lab environment in Isaac Sim and implemented ROS interfaces for six LiDAR models and an IMU, plus ROS control test nodes for a Ranger Mini robot.
- As project lead, coordinated the schedule and integrated the modules of a six-person team into the final deliverable.
- This project seeded my later work: the industrial digital twin (mold polishing) and the validation environment I now build at work.
PROBLEMWhy simulation
Outdoor environments like greenhouses change with seasons and weather, making repeated validation of autonomy algorithms difficult. You need a simulation that faithfully replicates the real environment — and an interface that lets the existing ROS stack plug in unchanged — to iterate without site visits.
METHODEnvironment, sensors, robot
- Environment — cleaned up 3D-scanned lab spaces and rebuilt them as Isaac Sim environments
- Sensors — implemented six LiDAR models with different scan patterns/channels plus an IMU, publishing ROS topics (LaserScan · PointCloud2)
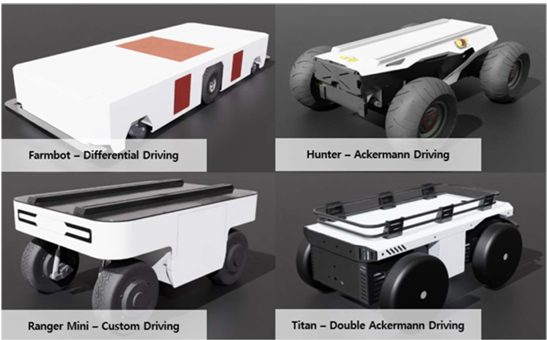
- Robot — Ranger Mini model with ROS control test nodes, plus robots for four drive types (Differential · Ackermann · Custom · Double Ackermann)
ROLEProject lead
I integrated the work of six people split across environment, sensor, and robot tracks. We agreed on interfaces first (topic names, frames, update rates) and managed weekly integration checkpoints, so the final integration had no surprises and the deliverable shipped on schedule.
RESULT
- Delivered an Isaac Sim autonomy environment with six LiDAR models, IMU, and robot control connected over ROS
- Completed the ETRI project "High-fidelity 3D greenhouse simulation environment & ROS interface"
DEMOVideo
 ▶YouTube
Integrated environment · sensors · robot demo